About
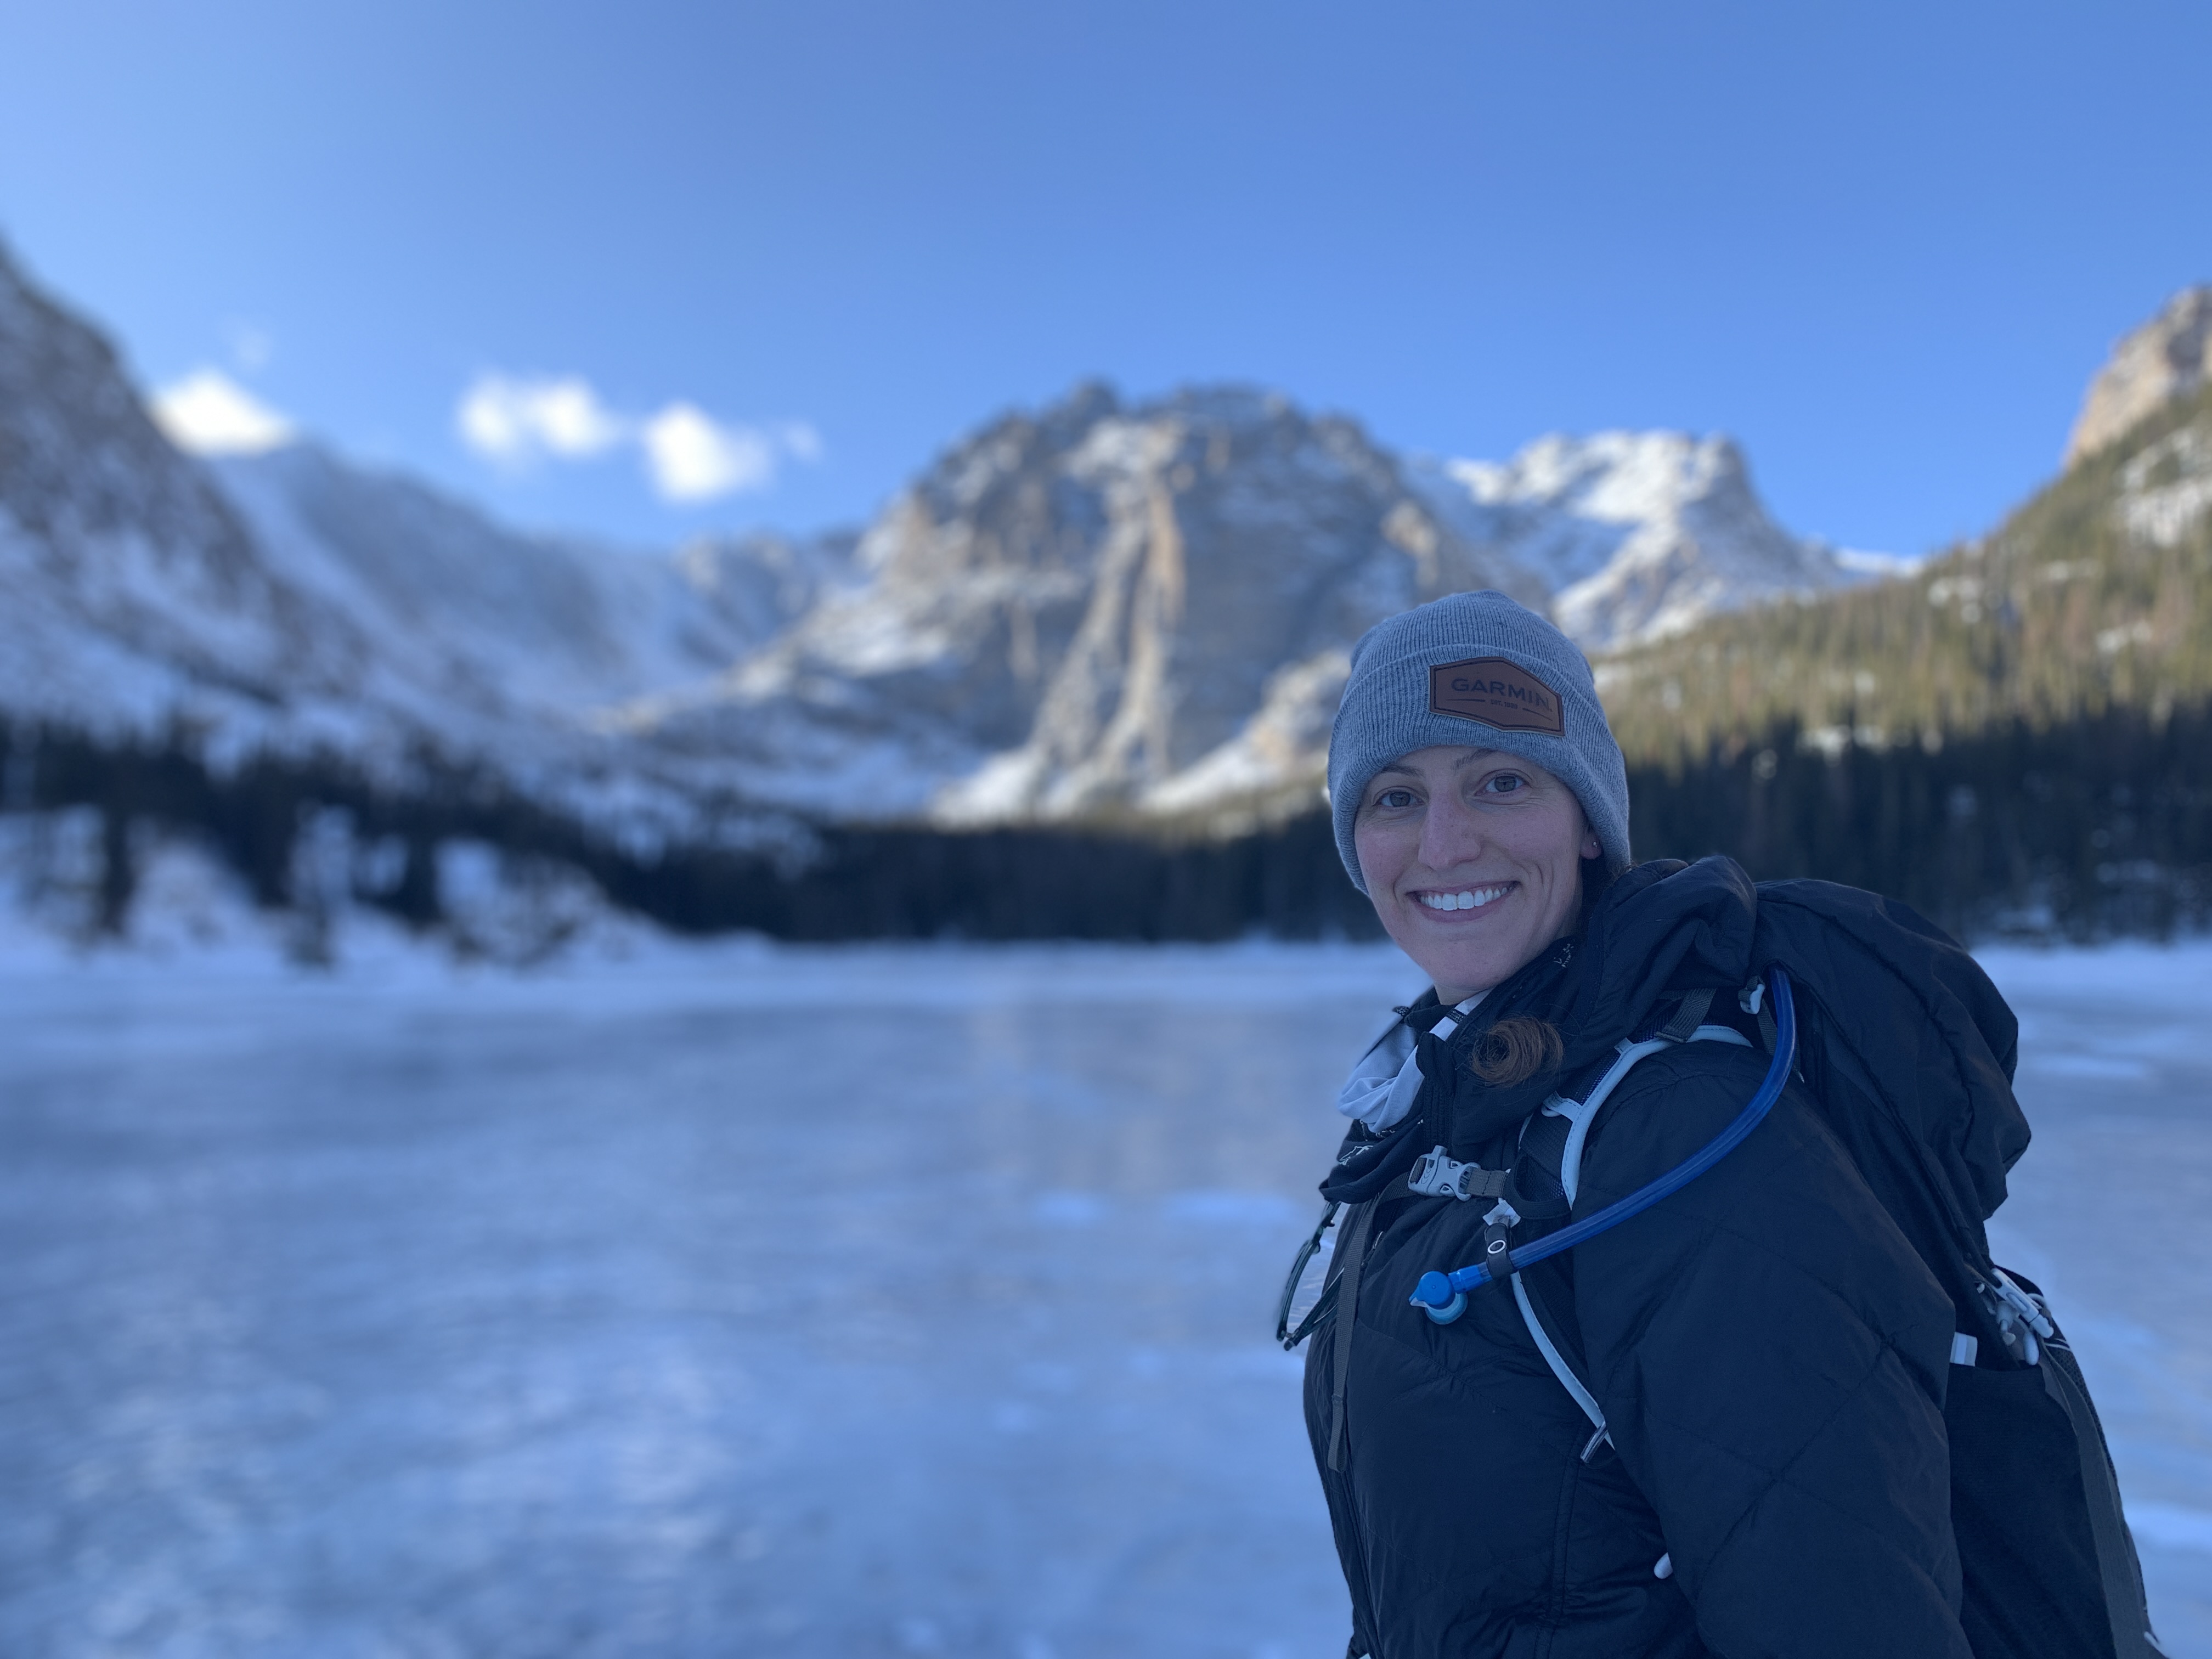
I am a PhD student and 2025 NDSEG Fellowship recipient at the University of Colorado Boulder, co-advised by Dr. Bradley Hayes of the Collaborative Artificial Intelligence and Robotics Laboratory and Dr. Christoffer Heckman of the Autonomous Robotics and Perception Group. My research centers on perception and sensor fusion for autonomous systems, risk-sensitive locomotion and navigation in unstructured environments, embodied AI for assistive robots, and collaborative multi-agent systems.
Currently open to
- Research internships for summer 2027 and summer 2028
- Visiting researcher positions at other universities. I would like to spend time in other labs to trade ideas and start collaborations, and I bring my own funding, so hosting me need not carry a financial commitment.
- Research collaborations on generative occupancy prediction, embodied scene understanding, multi-agent exploration, and risk-sensitive locomotion
- Research scientist and postdoctoral positions from 2028, when I expect to complete my PhD
Reach me on LinkedIn, or see the contact page.
Primary Research Interests
My recent work explores diffusion-based occupancy prediction for exploration, mapping, and long-horizon planning in mobile robots. I develop algorithms and AI models that enable mobile robots to perceive, predict, and act effectively in complex, partially observed, and egocentric environments. My work focuses on: multi-modal machine perception for 3D scene understanding, generative occupancy modeling, and Vision–Language–Action (VLA) models that unify perception, language, and control for grounded decision-making.